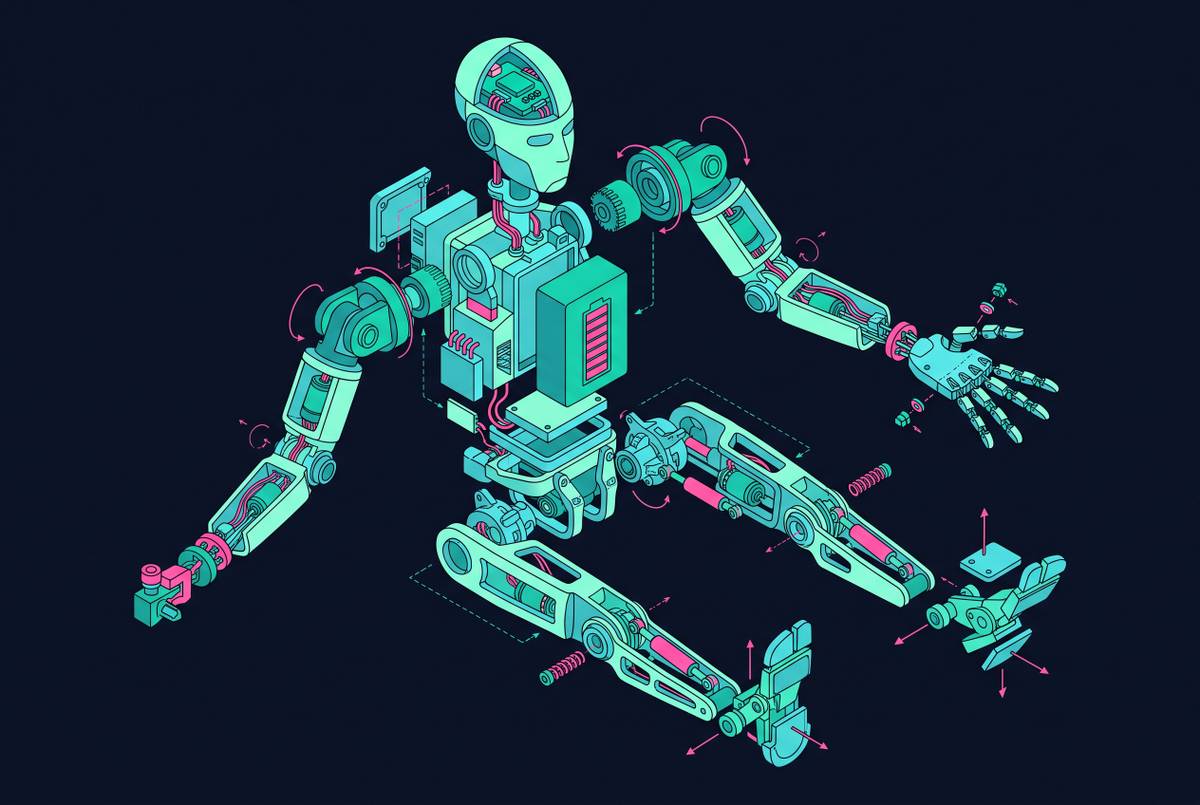
1X Technologies NEO Robot Hardware Architecture
Safety through biomimicry: how 1X built compliance into every layer of NEO.
Declan Ó Briain
5 stories
Safety through biomimicry: how 1X built compliance into every layer of NEO.
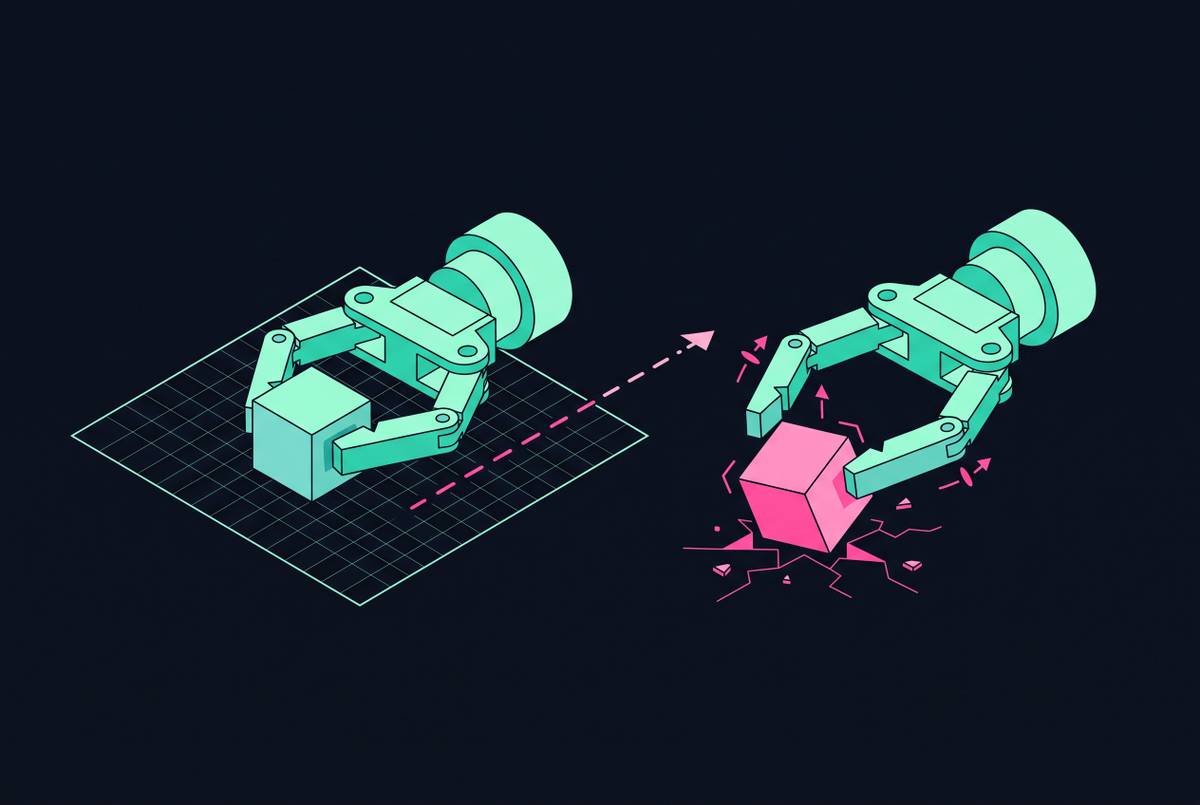
Contact physics discrepancies are the primary culprit behind manipulation failures.
Robots struggle to grasp objects safely without sensing friction and slip, not just pressure.
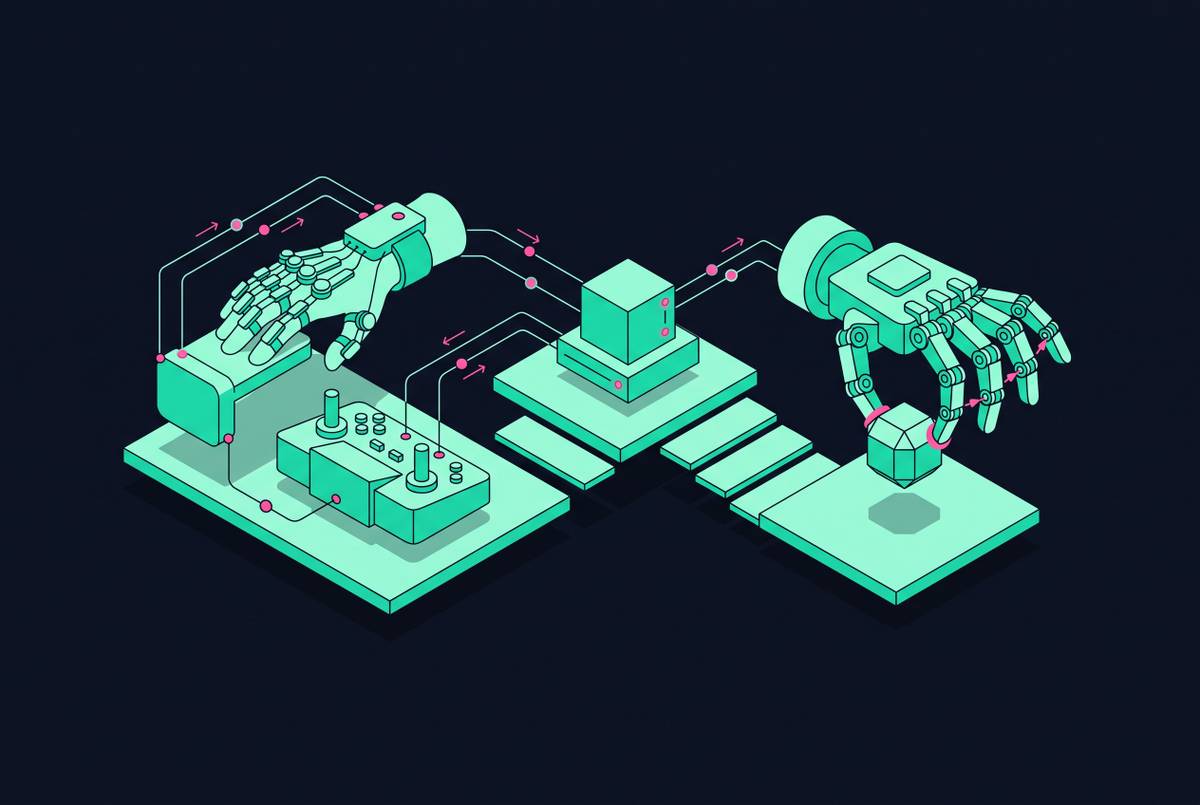
Teleoperation interfaces are the bottleneck limiting how fast robots can learn dexterous skills.
A denoising approach to action generation solved robot manipulation's hardest problem.